
Loading…
Loading…
Creator · nasa-jpl
View original source ↗What it is:
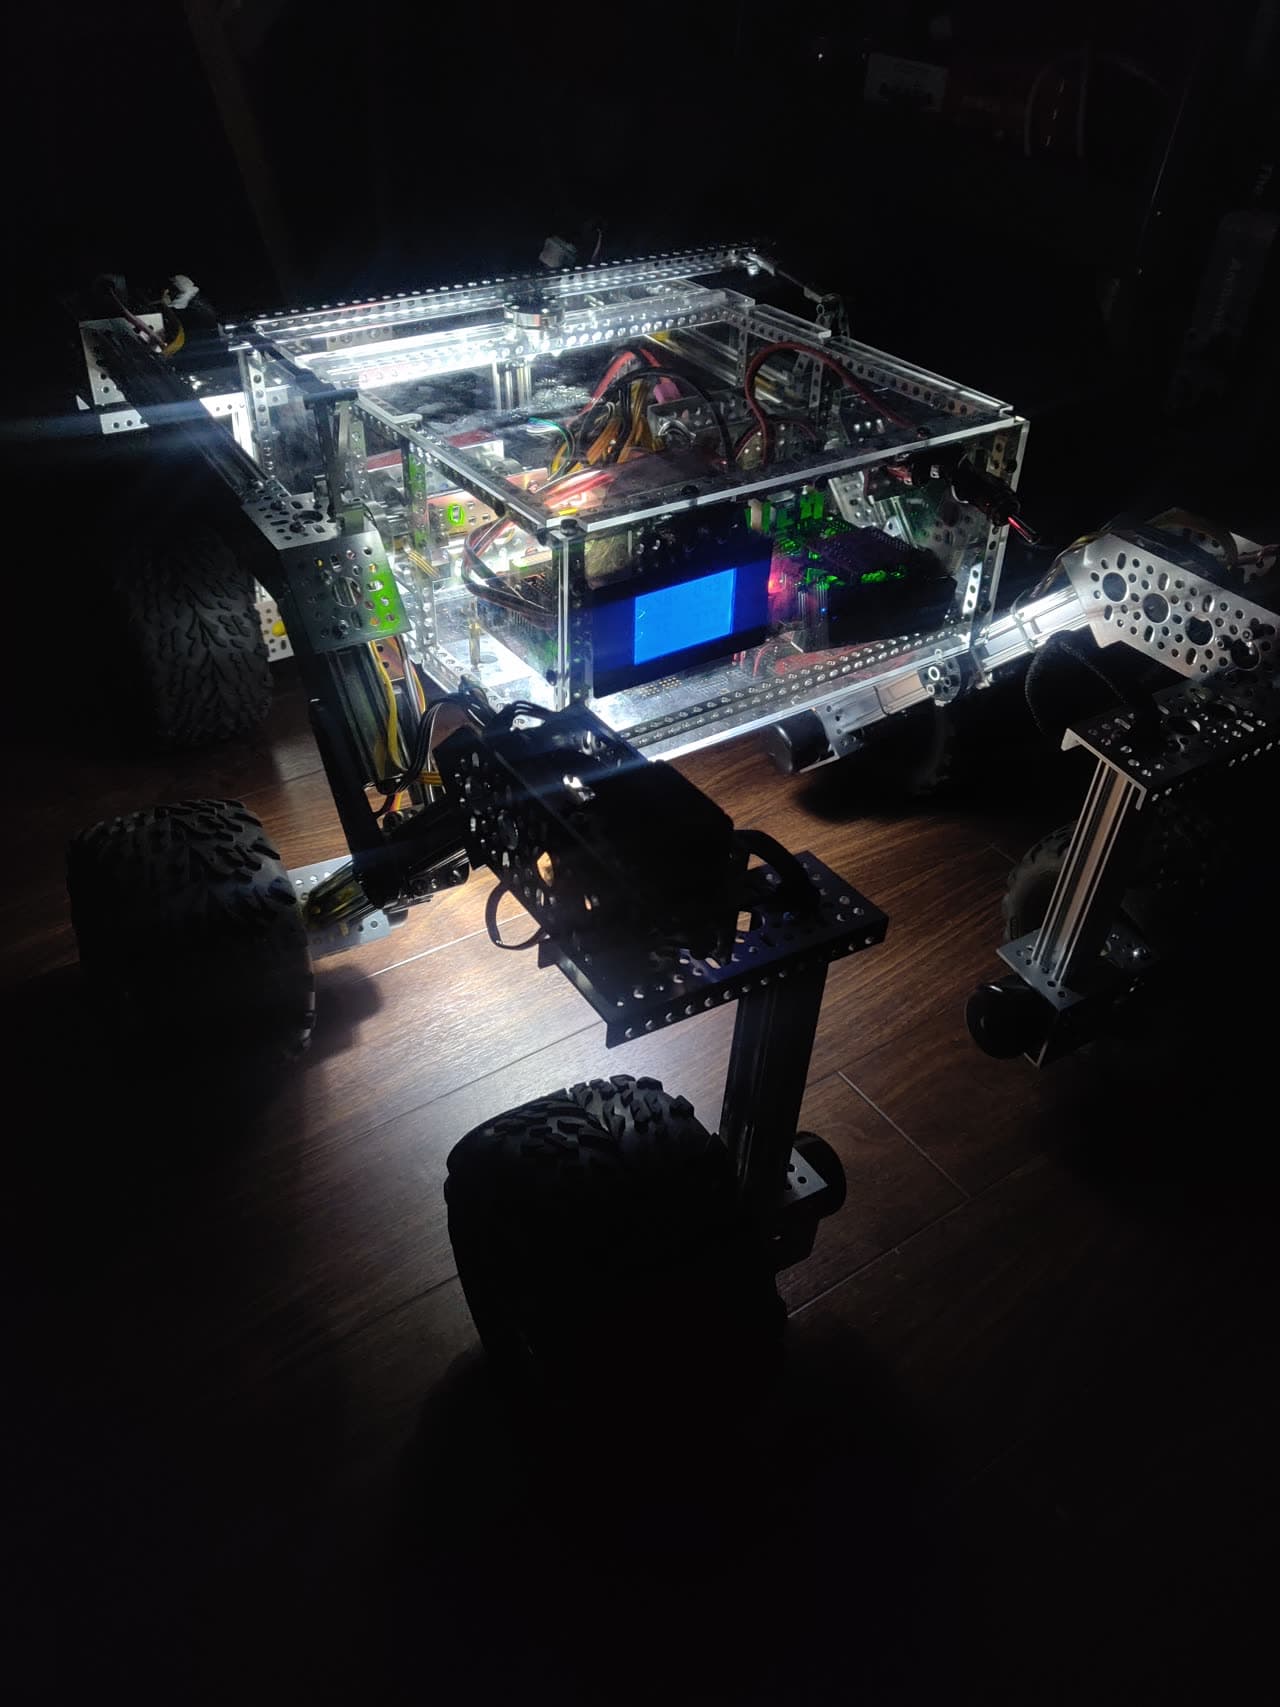
The Open Source Rover is an open-source hardware project released by NASA JPL. It is a scaled-down replica of the six-wheeled rover design JPL uses for Mars exploration, built entirely from consumer-grade commercial off-the-shelf (COTS) parts. The project began in 2017 and remains active today, and it has received official OSHW open-source hardware certification.
Hardware list and approximate cost:
Ten motors drive six wheels. The rover has an aluminum chassis built mainly from off-the-shelf GoBilda parts, with a Raspberry Pi as the control computer. A 7.2Ah battery provides approximately three hours of runtime. The official estimated cost for the complete rover is about $1,600, excluding shipping and tools.
Build overview:
1. Order all parts from GoBilda and other suppliers according to parts_list
2. Build the cable harnesses first, then solder and assemble the PCB
3. Assemble the chassis, the two rocker-bogie units, and the drive/steering motor assemblies
4. Integrate the cables and electronics into the mechanical structure
5. Configure the control software on the Raspberry Pi by following the osr-rover-code repository tutorial
6. Once everything is assembled, complete the drive tests, then add sensor extensions as needed
Getting-started advice:
NASA estimates that a complete build requires at least 100 person-hours. It involves metal cutting, soldering and wiring, plus basic Linux, ROS, and Python knowledge. Read the experience posts in the Slack community first, and do not underestimate the workload.Models & stability
Recommended models
Keep exploring
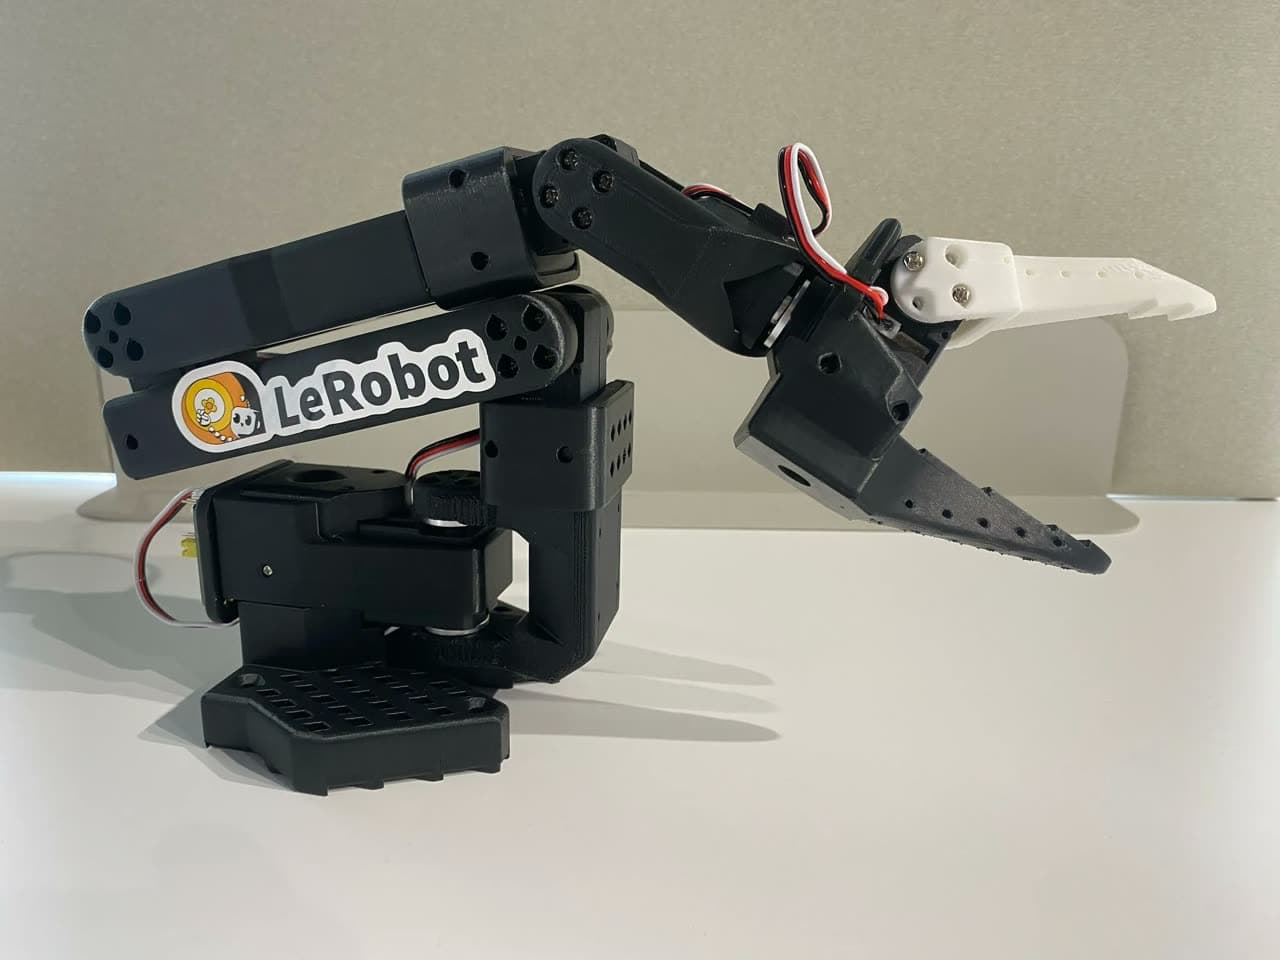
A low-cost standardized robotic arm kit. A leader and follower arm work with the LeRobot library for teleoperation and imitation-learning data collection. The full system can be assembled from online purchases and 3D-printed parts, with both arms costing about $230.
Prompt
What it is: The SO-101 is a standardized open-source robotic arm developed by RobotStudio in collaboration with the Hugging Face LeRobot team. It is the successor to the SO-100, with improved cable routing and assembly that does not require
An AI assistant running on a $5 ESP32-S3 chip. It uses pure C with no Linux or Node.js, communicates through Telegram, calls Claude or GPT to complete tasks, and remembers history across restarts.
Prompt
What it is: MimiClaw packs a complete set of AI agent capabilities—reasoning, tool use, and reading and writing memory—into an ESP32-S3 chip that does not run Linux. It is implemented in pure C, sends and receives messages through Telegram,

Autonomous Lamp is an open-source desktop mechanical lamp with a cream-white mechanical frame and a ring light strip. It has no screen and interacts with people through multi-axis head turns, shaking, and changing light. The author calls it fully open source and extensible.
Prompt
一款超有意思的皮皮灯 谁能拒绝一盏像皮克斯动画里一样“活过来”的桌面台灯?Autonomous Lamp 凭借独特的奶白机械骨架和环形灯带设计,直接把桌面美学拉满!它不需要任何屏幕,而是通过多轴机械结构的转头、摇晃和光影变化来与你完成互动,同时还拥有完全开源的拓展能力。…
Each detail page keeps the original result, the prompt, and retest evidence in one reading path.