
Loading…
Loading…
Creator · PetoiCamp
View original source ↗What it is:
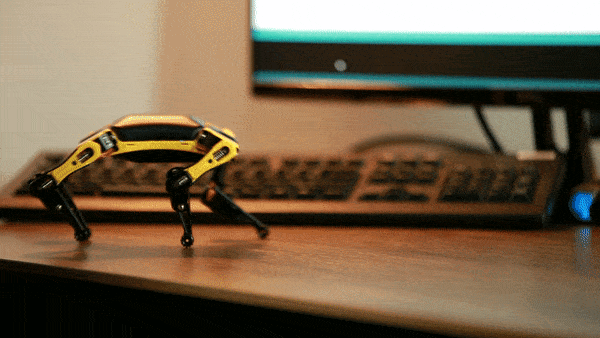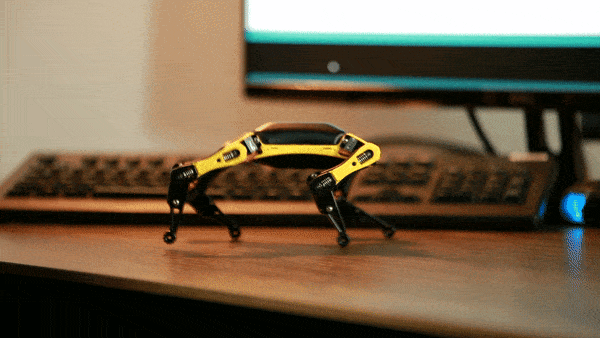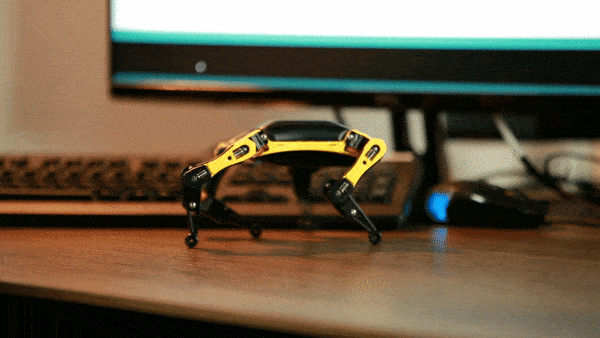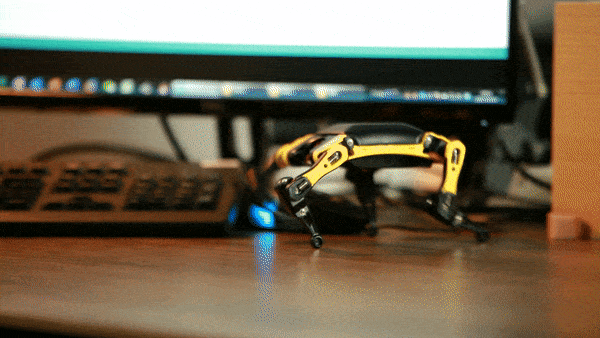
OpenCat is an open-source Arduino + Raspberry Pi quadruped robotics framework maintained by Petoi. Founder Rongzhong Li began developing it in a Wake Forest University dorm room in 2016, with the goal of making agile quadruped robots accessible to researchers, educators, and hobbyists. It now powers two product lines: the Bittle robot dog and the Nybble robot cat.
Hardware list and approximate cost:
The core component is the ATmega328P-based NyBoard controller, which can coordinate up to 12 servos for walking, running, jumping, and even backflips. Optional additions include a sensor pack, camera module, or a Raspberry Pi/Jetson Nano as an AI coprocessor. The complete robot is typically purchased as a Bittle or Nybble kit. Refer to the current prices on Petoi’s official website for the actual purchase price; this repository’s README does not provide a single standard price for a complete robot.
Build overview:
1. Clone the repository and remove the -main/branch-name suffix from the folder name
2. Open OpenCat.ino and select the robot model (BITTLE/NYBBLE) and board version (NyBoard_V1_0, etc.)
3. Comment out MAIN_SKETCH to enter configuration mode, then upload the firmware
4. Set the Serial Monitor to no line ending and 115200 baud, then follow the prompts to zero the joints and calibrate the IMU, with the body placed flat on a table
5. After calibration, uncomment MAIN_SKETCH, switch back to main program mode, and upload again
6. Control the robot using the infrared remote, Petoi App, Python, or serial commands
Getting-started advice:
This repository is for the older NyBoard hardware based on the ATmega328P. For the newer ESP32/BiBoard hardware, use the OpenCatESP32 repository. The code will not match if you buy the wrong board.
Note: The cost tier is an editorial estimate; no official total price for the complete robot has been published.Models & stability
Recommended models
Keep exploring
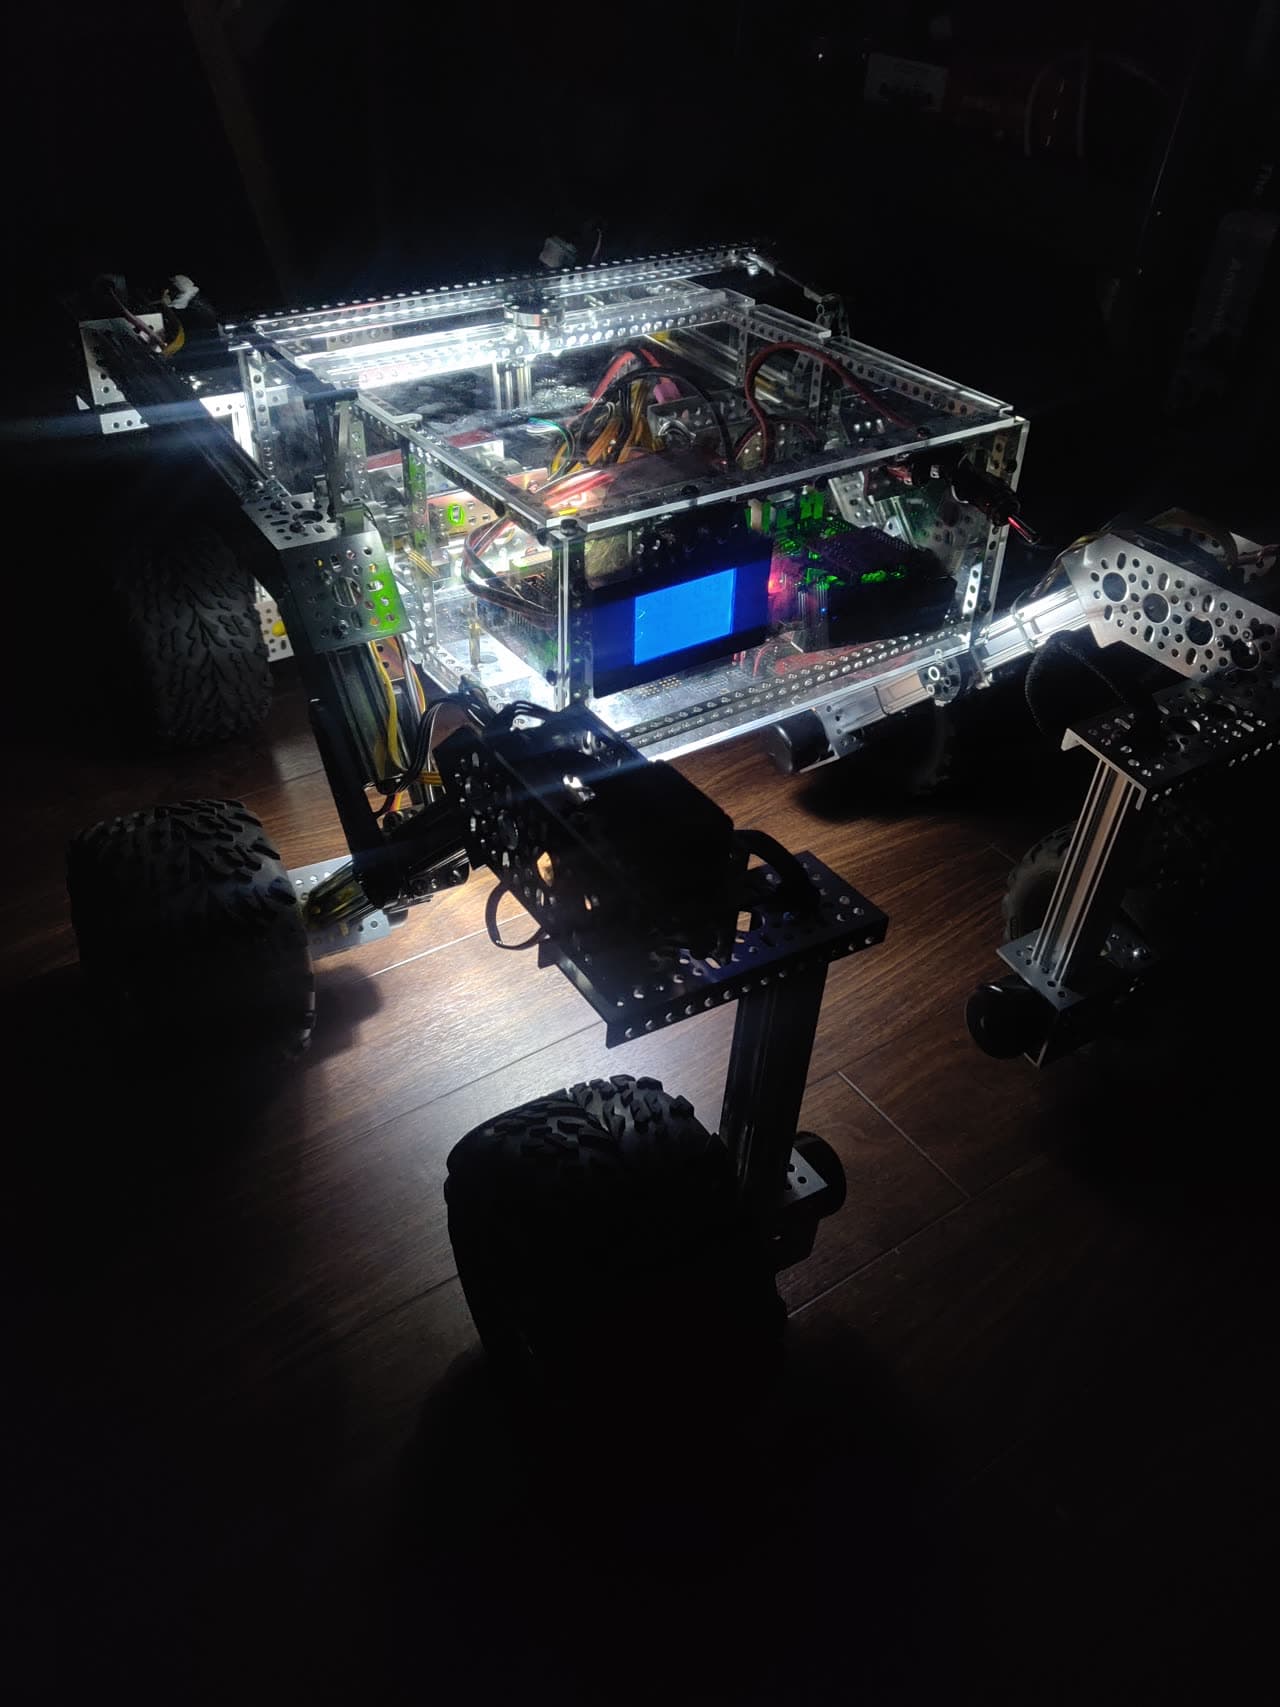
A complete hardware design released by JPL for a six-wheeled Mars rover. Its rocker-bogie suspension and differential pivot keep every wheel in contact with the ground while climbing. A Raspberry Pi serves as the brain, and the full build costs about $1,600.
Prompt
What it is: The Open Source Rover is an open-source hardware project released by NASA JPL. It is a scaled-down replica of the six-wheeled rover design JPL uses for Mars exploration, built entirely from consumer-grade commercial off-the-shel
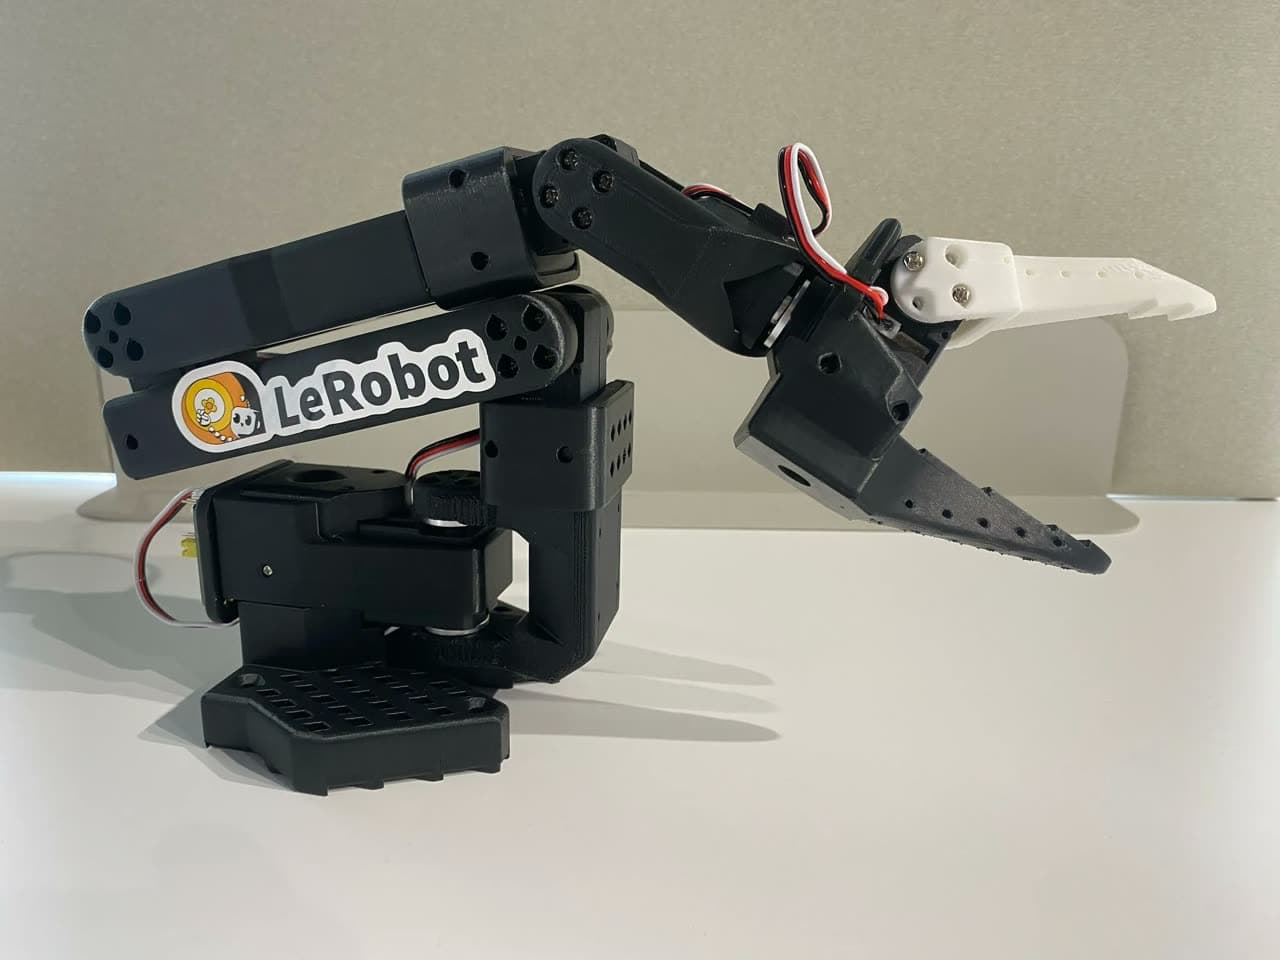
A low-cost standardized robotic arm kit. A leader and follower arm work with the LeRobot library for teleoperation and imitation-learning data collection. The full system can be assembled from online purchases and 3D-printed parts, with both arms costing about $230.
Prompt
What it is: The SO-101 is a standardized open-source robotic arm developed by RobotStudio in collaboration with the Hugging Face LeRobot team. It is the successor to the SO-100, with improved cable routing and assembly that does not require
An AI assistant running on a $5 ESP32-S3 chip. It uses pure C with no Linux or Node.js, communicates through Telegram, calls Claude or GPT to complete tasks, and remembers history across restarts.
Prompt
What it is: MimiClaw packs a complete set of AI agent capabilities—reasoning, tool use, and reading and writing memory—into an ESP32-S3 chip that does not run Linux. It is implemented in pure C, sends and receives messages through Telegram,
Each detail page keeps the original result, the prompt, and retest evidence in one reading path.