GoodCase.aiAI News · Radar↗AI Map↗Course · LearnPrompt↗
ProjectsGoodCase.aiAI News Radar ↗AI Map ↗LearnPrompt ↗
GoodCase.aiGoodCase.aiAI Prompt Case Collection
GoodCase.ai
RankingsCasesSkillsFavoritesSubmitDailyJoin us
中文EN
Agent Access →

Projects

AI News · Radar ↗AI Map ↗Course · LearnPrompt ↗
GoodCase.aiGoodCase.aiAI Prompt Case Collection
RankingsCasesSkillsFavoritesSubmitDailyJoin us
中文EN
Agent Access →

Loading…

GoodCase.ai · AI Prompt Case Collection
DSH PluginsChangelogFeedback
ModelsCreatorsSeedance 2.5Seedance 2.0GPT Image 2GeminiNano Banana ProClaudeClaude Opus 5.5Grok ImagineVeoKlingQwen ImageGPT Image 1.5MiniMax H3

Creator · Worth learning

SIGRobotics-UIUC

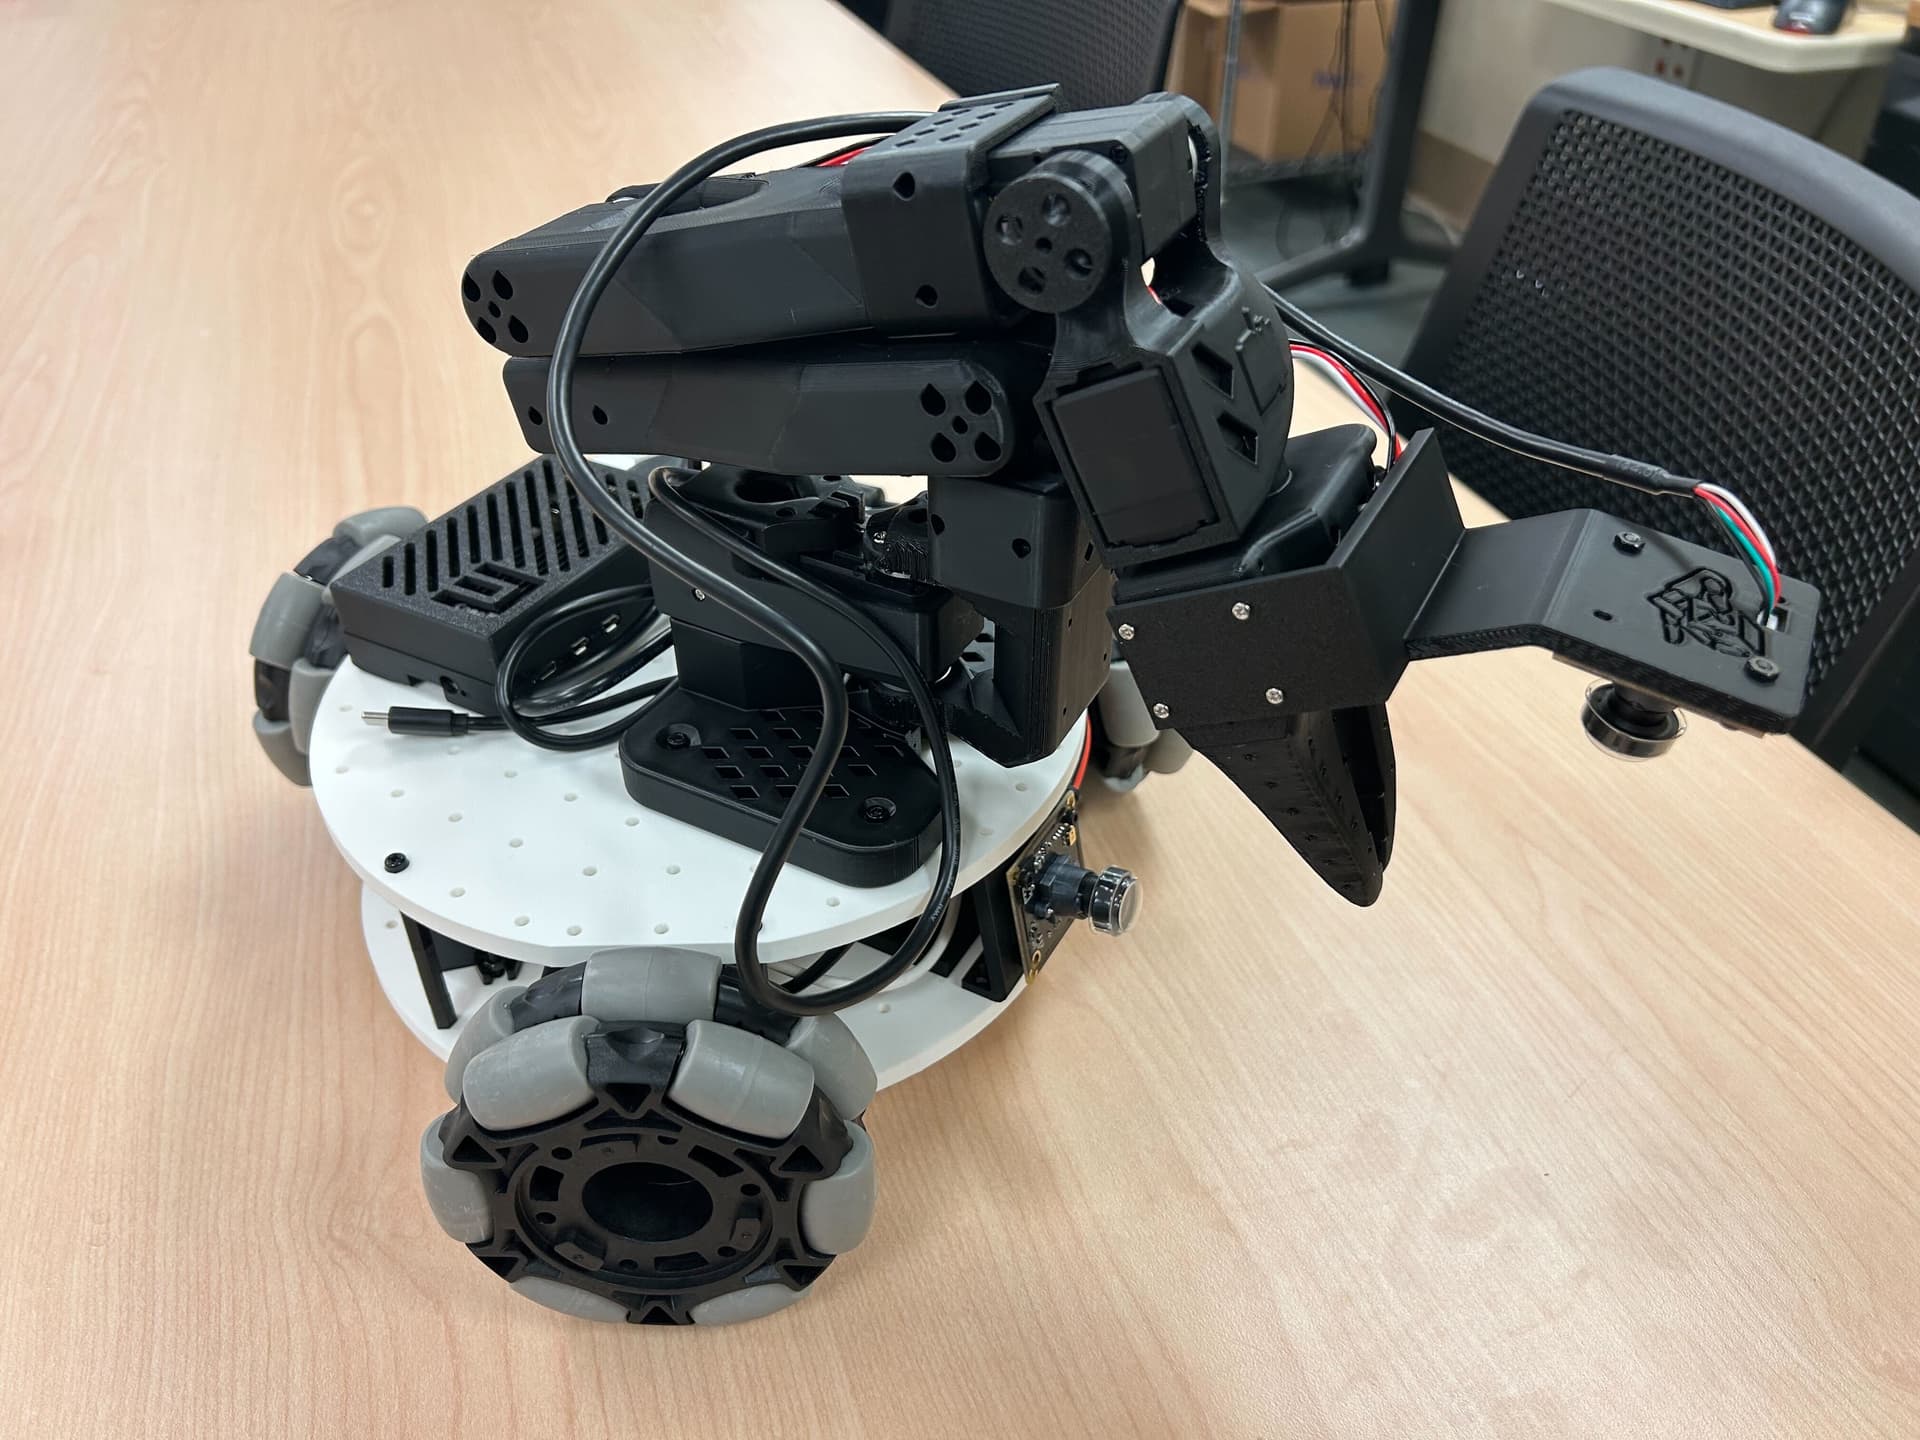
SIGRobotics-UIUC focuses on AI hardware and software loops and is active on GitHub. “LeKiwi Low-Cost Mobile Robotic Arm” is the current representative case, built with LeRobot with a 87% stability reference.

SU
Creator profile
SIGRobotics-UIUC
Cases
1
GitHub
Average
87
Stability
Source interactions
1386
Total
Evidence
1
L1 / L2 Cases
Latest work
02/05/2025
Newest sourcePublishedAt across published cases

Representative cases

Start with the representative work.

Back to creators
LeKiwi Low-Cost Mobile Robotic Arm
AI HardwareGitHubAdded 08/19/2026

LeKiwi Low-Cost Mobile Robotic Arm

A low-cost mobile robotic arm combining a three-wheel omnidirectional base with a SO-ARM101 robotic arm. It works with the LeRobot library for teleoperation and data collection, costing approximately $482 for the complete 12V version and $499 for the 5V version.

Skill · Open-source hardware build

Prompt

What it is: LeKiwi is a low-cost mobile manipulation platform created by the SIGRobotics club at the University of Illinois Urbana-Champaign. It combines a three-wheel omnidirectional Kiwi drive base with a SO-ARM101 robotic arm and later b

Source heat · GitHub
29
Stability
87
View case →

Creator pages aggregate existing cases so every judgment traces back to the work.