
Loading…
Loading…
Creator · TheRobotStudio
View original source ↗What it is:
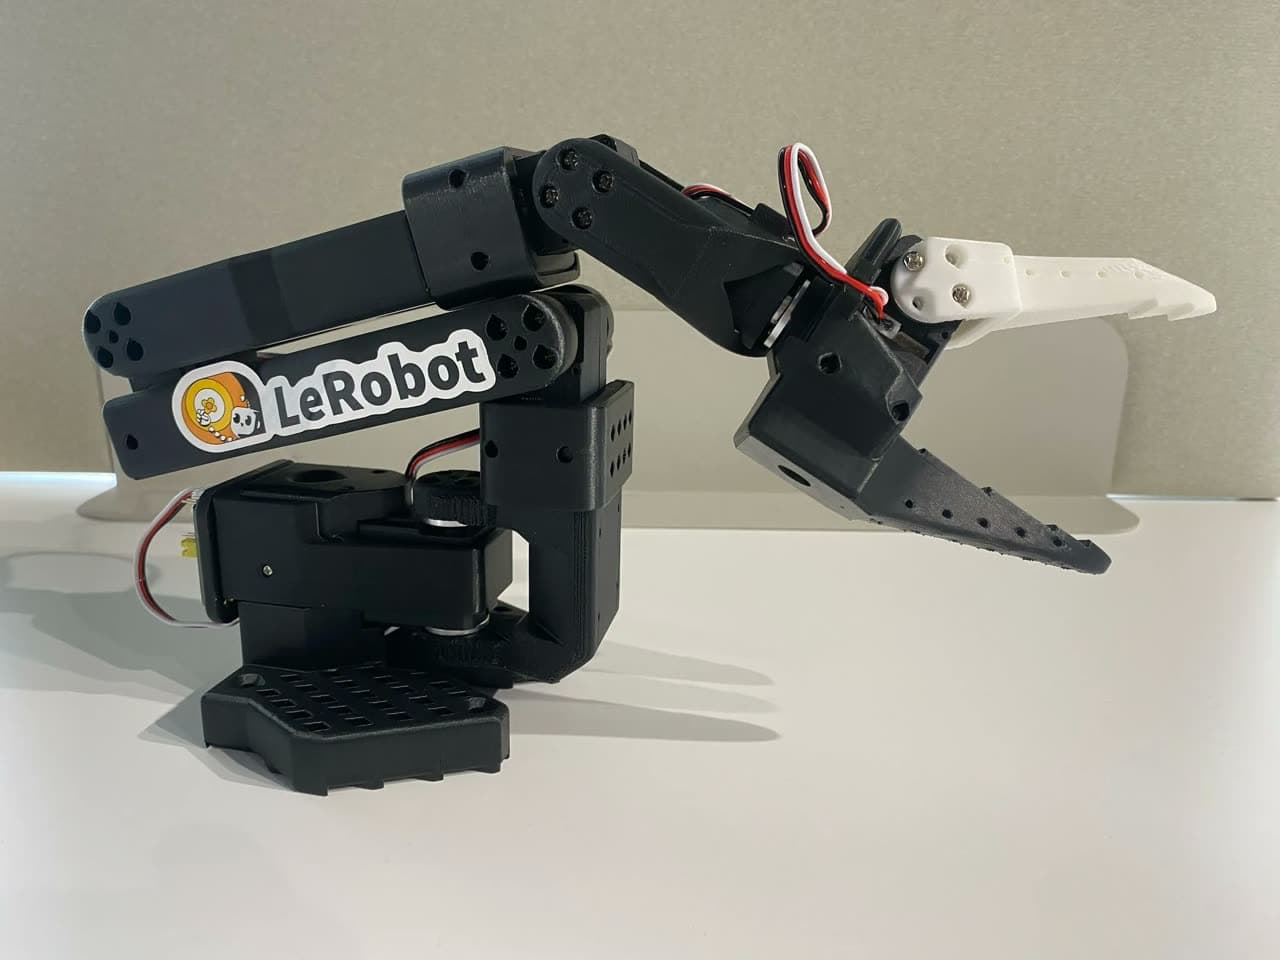
The SO-101 is a standardized open-source robotic arm developed by RobotStudio in collaboration with the Hugging Face LeRobot team. It is the successor to the SO-100, with improved cable routing and assembly that does not require disassembling the gears. It is designed specifically for teleoperation and imitation learning with the open-source LeRobot library.
Hardware list and approximate cost:
The leader and follower arms both use STS3215 servos: six for the follower arm and six for the leader arm, with slightly different models. They are paired with a Waveshare motor-control board and 3D-printed structural parts. According to the official BOM, both arms together—one leader and one follower—cost approximately $229.88. A follower arm alone costs about $121.94. Neither figure includes 3D printing, taxes, or shipping.
Overview of replication steps:
1. Follow the Sourcing Parts list to purchase the servos and control board in the US, Europe, China, or Japan
2. 3D-print the leader and follower arm components in PLA+ using a 0.4 mm nozzle and 0.2 mm layer height, or use the officially recommended print settings
3. Before printing, use the Gauge file to verify the printer’s accuracy
4. Assemble the leader and follower arms according to the official Assembly Guide
5. Configure the servos using Feetech software or directly through the LeRobot library
6. Follow the official LeRobot tutorial to set up teleoperation and collect demonstration data
Getting-started advice:
STS3215 servos come in 7.4 V and 12 V versions, so do not mix them up. The 12 V version provides more torque but requires a 12 V power supply. It is recommended only when the follower arm needs higher torque.Models & stability
Recommended models
Keep exploring
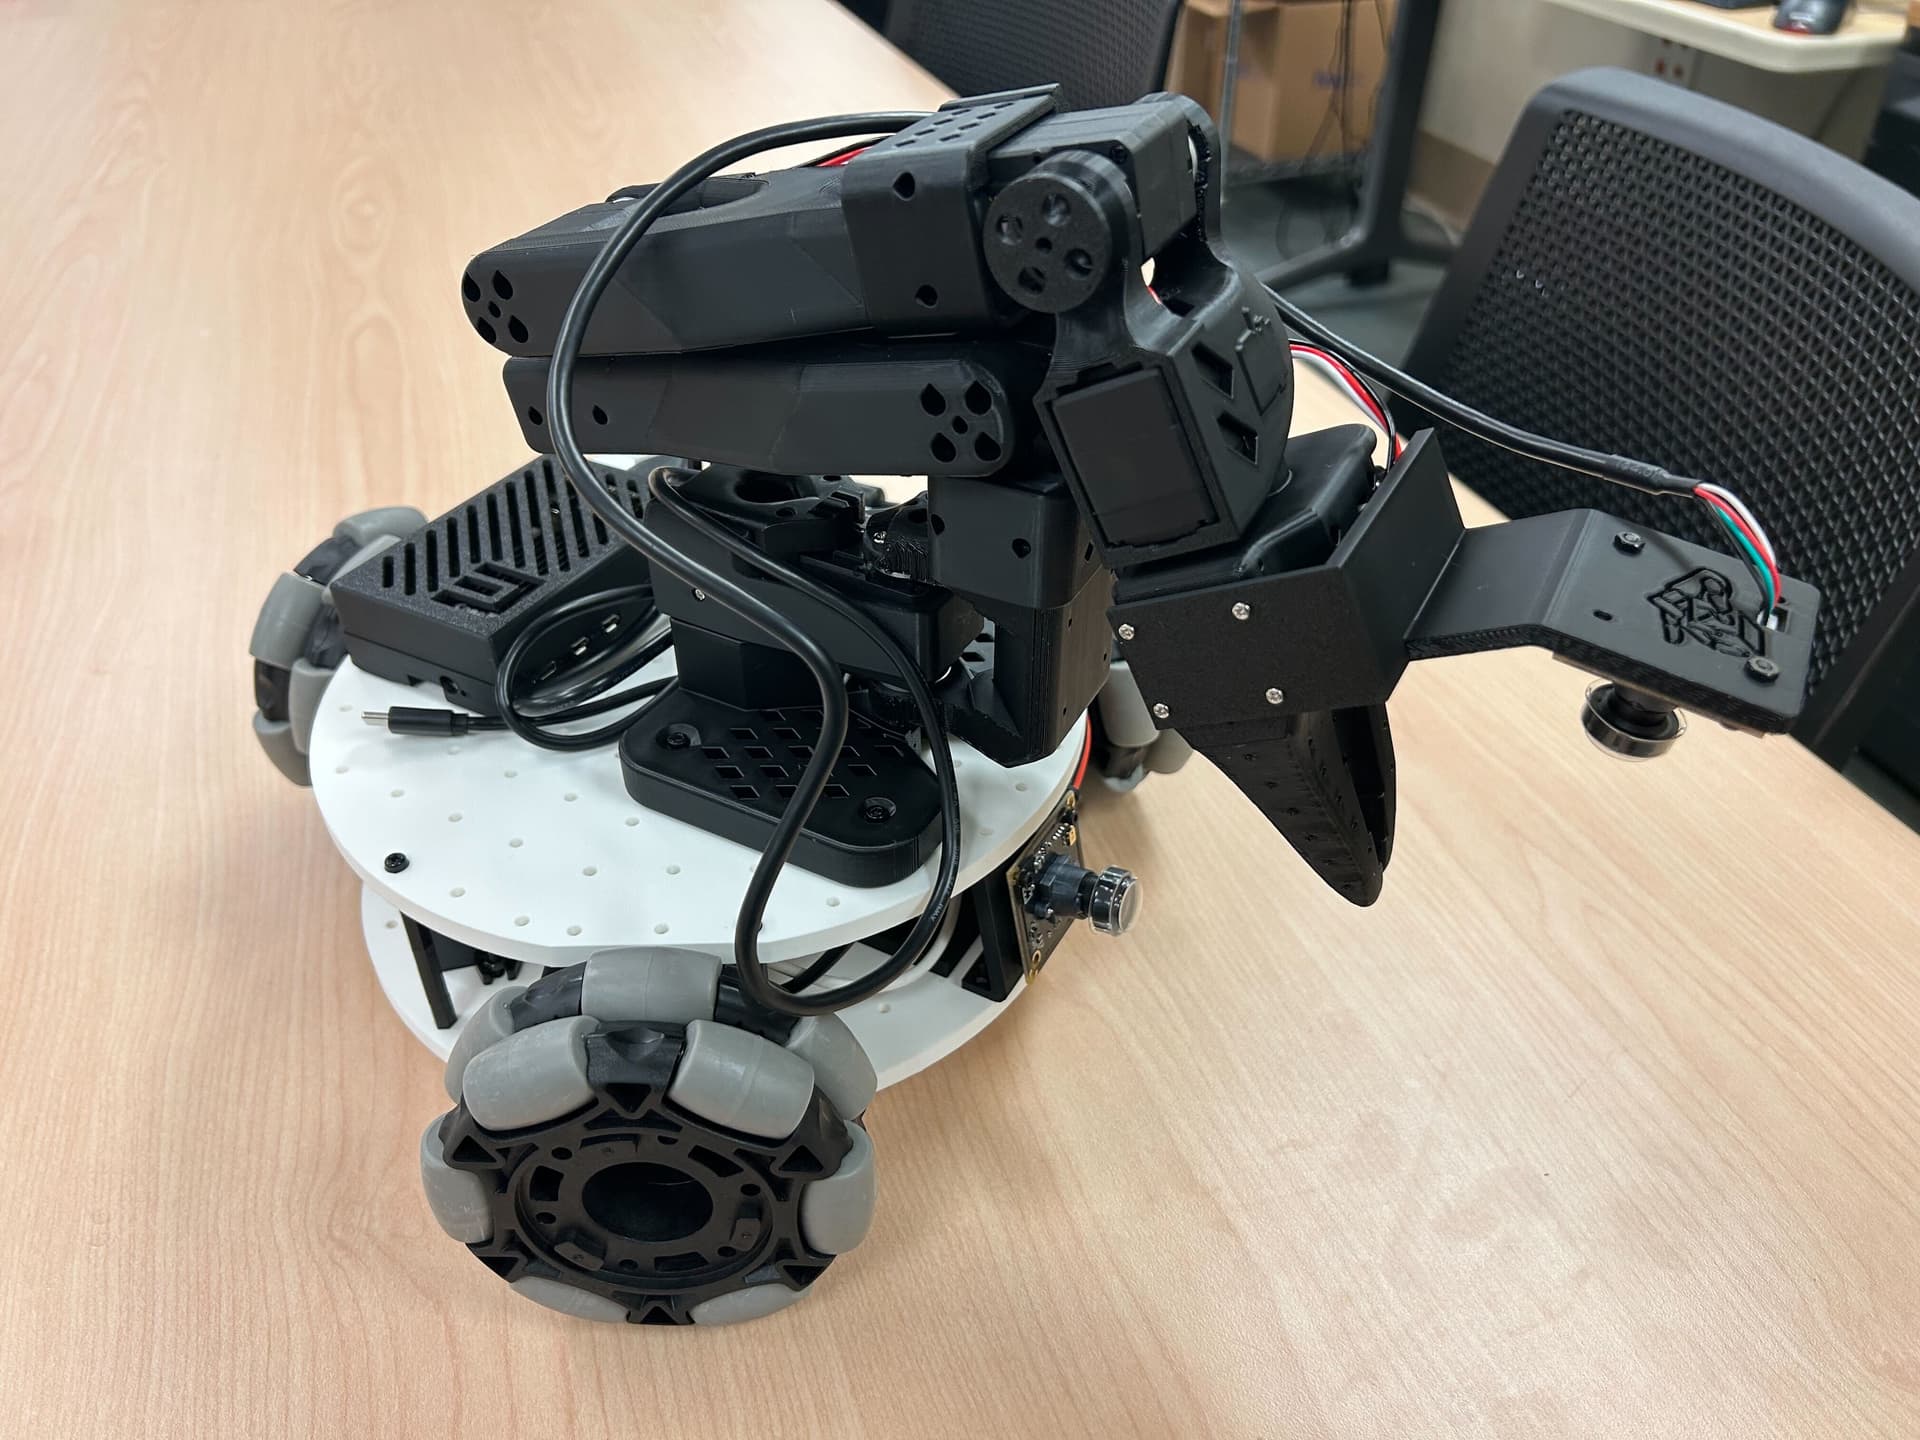
A low-cost mobile robotic arm combining a three-wheel omnidirectional base with a SO-ARM101 robotic arm. It works with the LeRobot library for teleoperation and data collection, costing approximately $482 for the complete 12V version and $499 for the 5V version.
Prompt
What it is: LeKiwi is a low-cost mobile manipulation platform created by the SIGRobotics club at the University of Illinois Urbana-Champaign. It combines a three-wheel omnidirectional Kiwi drive base with a SO-ARM101 robotic arm and later b
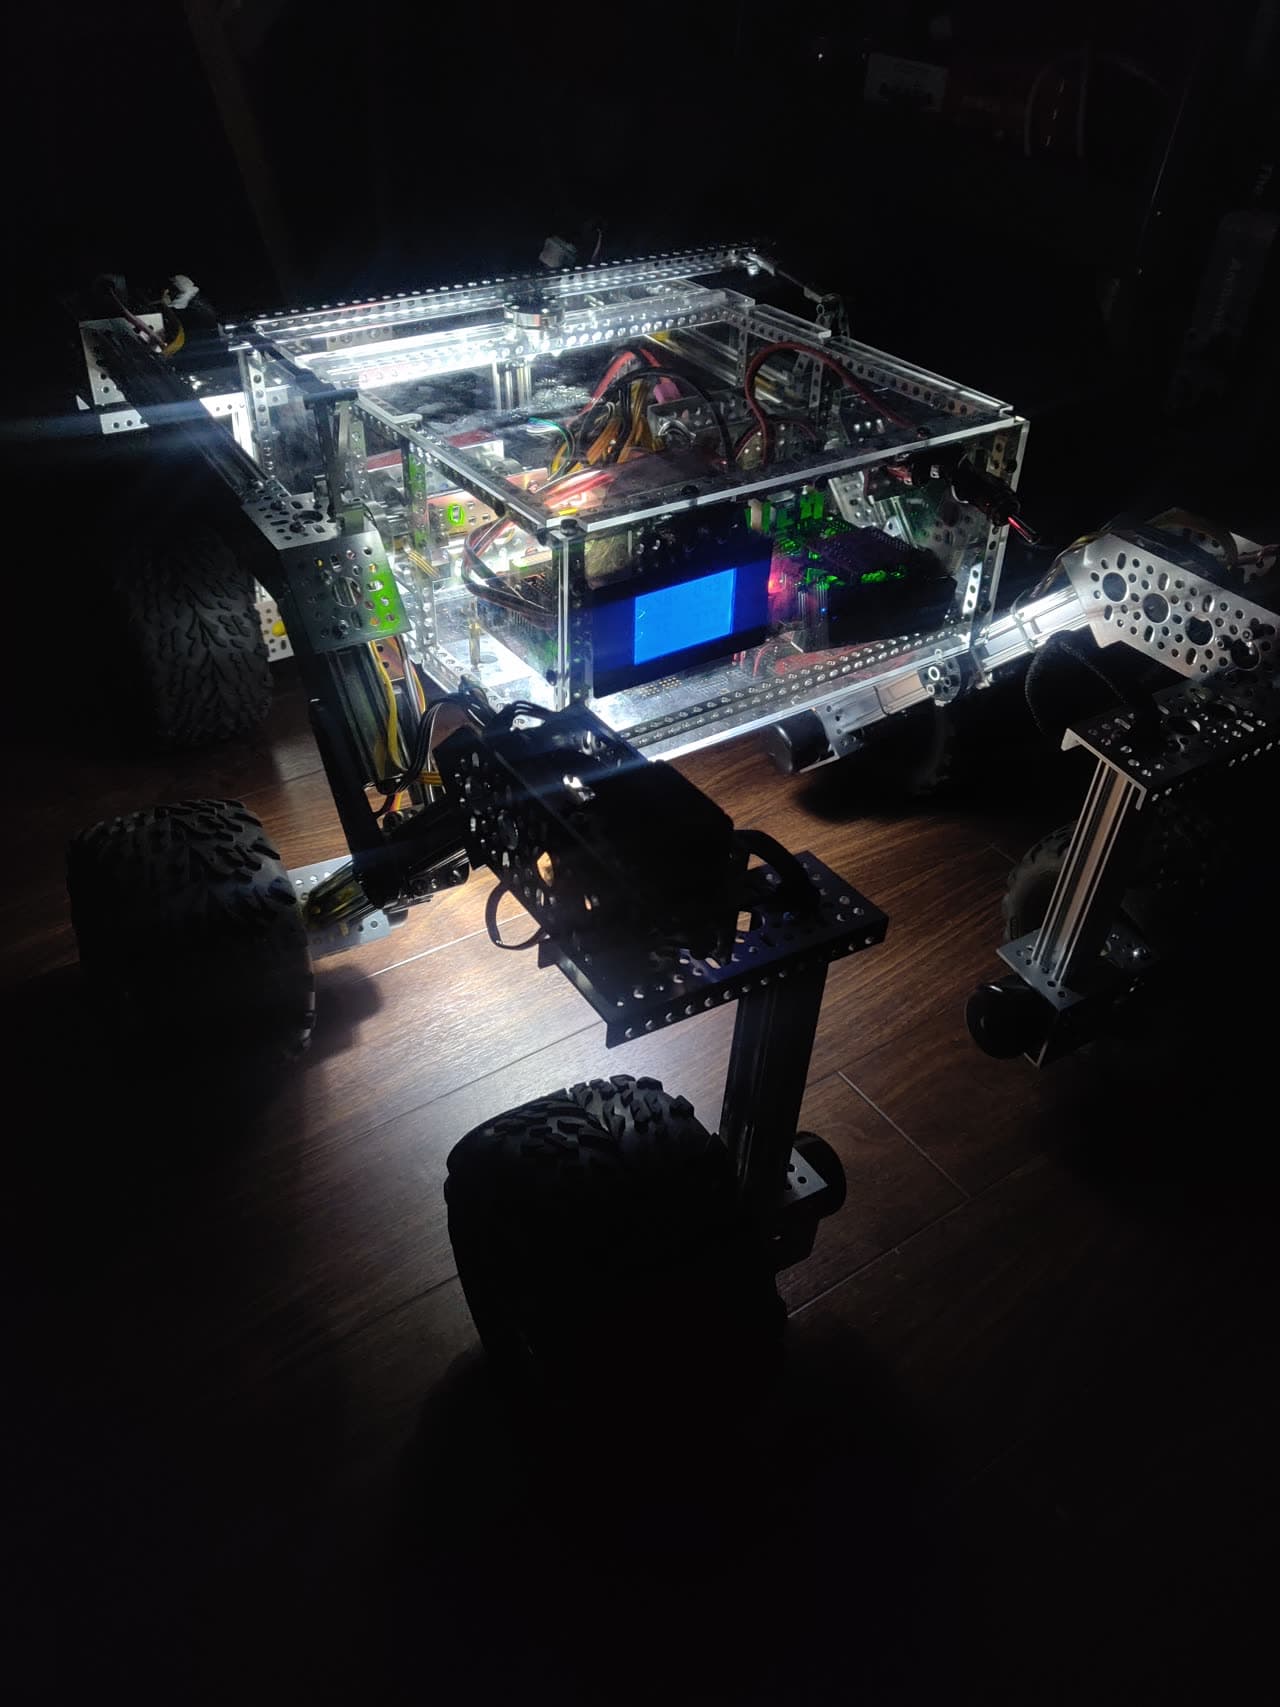
A complete hardware design released by JPL for a six-wheeled Mars rover. Its rocker-bogie suspension and differential pivot keep every wheel in contact with the ground while climbing. A Raspberry Pi serves as the brain, and the full build costs about $1,600.
Prompt
What it is: The Open Source Rover is an open-source hardware project released by NASA JPL. It is a scaled-down replica of the six-wheeled rover design JPL uses for Mars exploration, built entirely from consumer-grade commercial off-the-shel
An AI assistant running on a $5 ESP32-S3 chip. It uses pure C with no Linux or Node.js, communicates through Telegram, calls Claude or GPT to complete tasks, and remembers history across restarts.
Prompt
What it is: MimiClaw packs a complete set of AI agent capabilities—reasoning, tool use, and reading and writing memory—into an ESP32-S3 chip that does not run Linux. It is implemented in pure C, sends and receives messages through Telegram,
Each detail page keeps the original result, the prompt, and retest evidence in one reading path.