
Verified installable Agent Skill
SKILL.md + .skillInstall into your agent.
npx skills add LearnPrompt/goodcase-lite --skill open-source-hardware-build --global --copy --yes --full-depthLoading…
GoodCase Official Skill · Shared method across creators
Lay out how to rebuild open-source robots, wearables, and e-ink devices: parts, firmware, and assembly.
9 Cases · 9 Creators · AI Hardware · Latest example 08/19/2026


Verified installable Agent Skill
SKILL.md + .skillnpx skills add LearnPrompt/goodcase-lite --skill open-source-hardware-build --global --copy --yes --full-depthMethod skeleton
Creator practice
Creator practices derived from this shared method, including versions not yet listed in the catalog.
No creator versions yet.
Creator evidence
Case evidence

Autonomous Lamp is an open-source desktop mechanical lamp with a cream-white mechanical frame and a ring light strip. It has no screen and interacts with people through multi-axis head turns, shaking, and changing light. The author calls it fully open source and extensible.
Prompt
一款超有意思的皮皮灯 谁能拒绝一盏像皮克斯动画里一样“活过来”的桌面台灯?Autonomous Lamp 凭借独特的奶白机械骨架和环形灯带设计,直接把桌面美学拉满!它不需要任何屏幕,而是通过多轴机械结构的转头、摇晃和光影变化来与你完成互动,同时还拥有完全开源的拓展能力。…
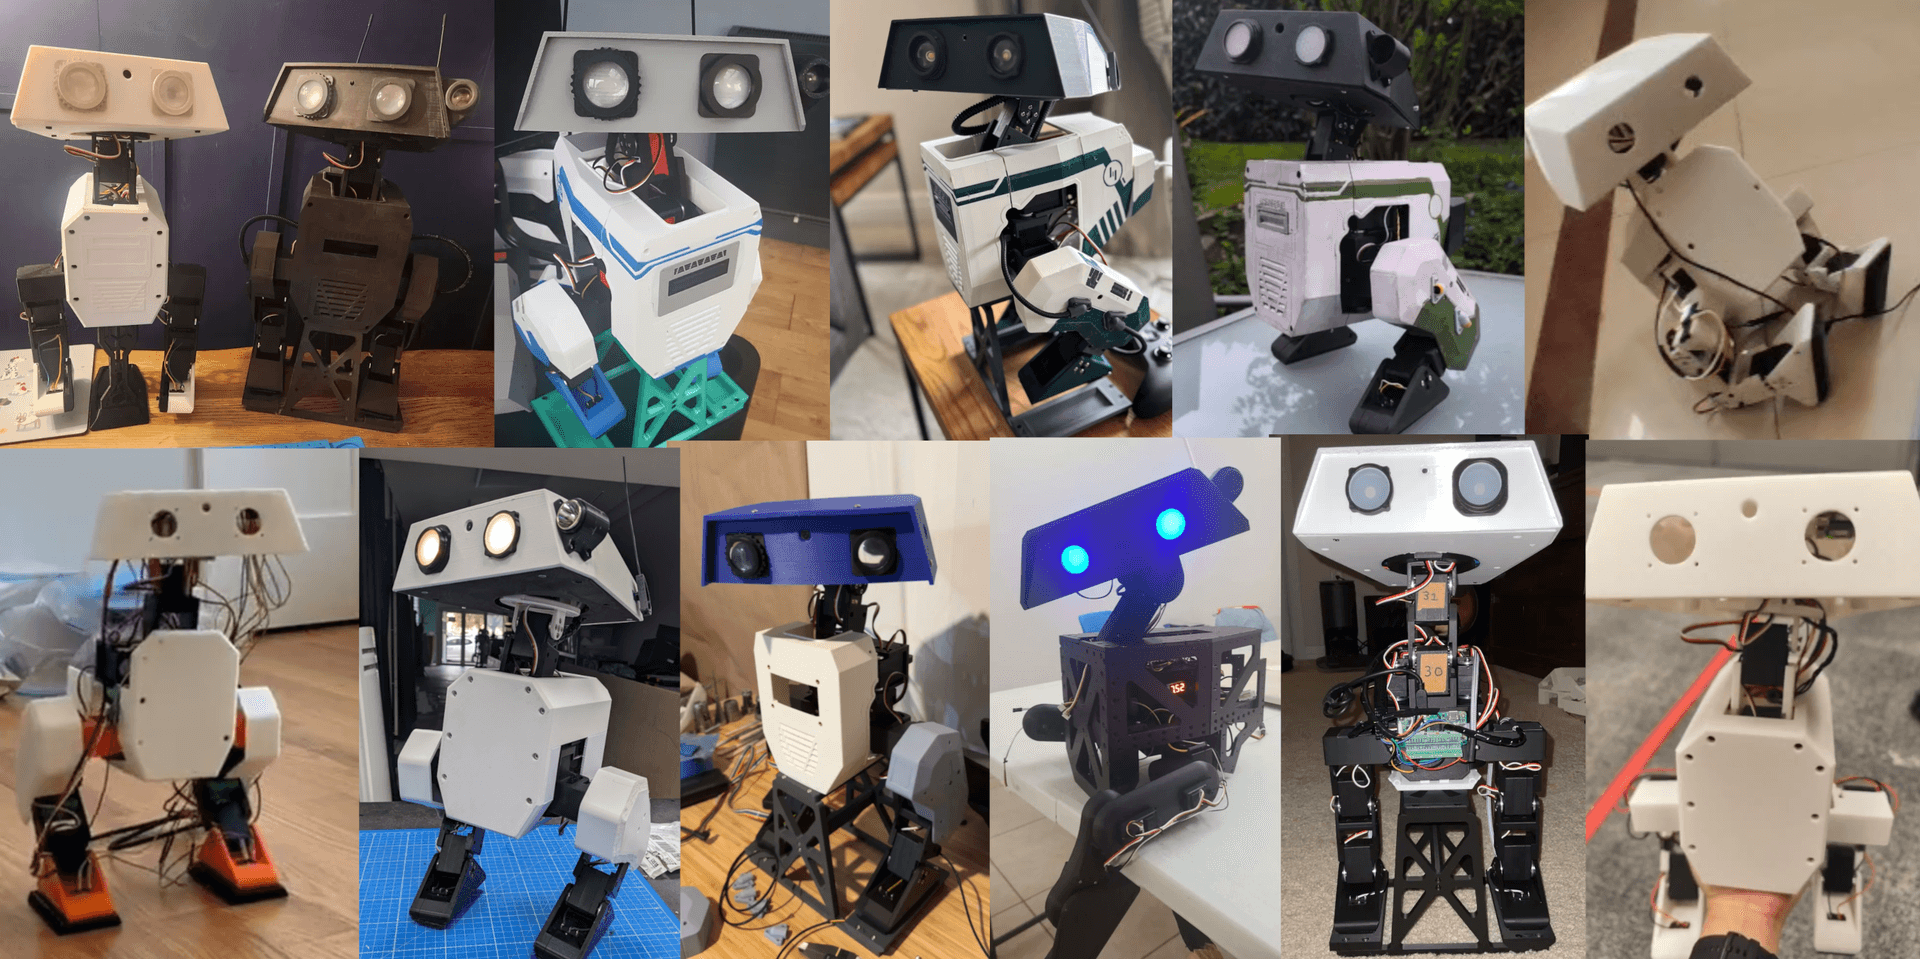
A desktop-sized replica of Disney’s BDX robot, standing 42 cm tall. Its reinforcement-learning gait has already been transferred from simulation to the real robot, and the official BOM cost is listed at under approximately $400.
Prompt
What it is: Open Duck Mini v2 is a miniature replica of Disney’s BDX droid. The biped stands 42 cm tall. The author describes the repository as “a work in progress”; many scripts are undocumented, and the repository will continue to be orga
An AI assistant running on a $5 ESP32-S3 chip. It uses pure C with no Linux or Node.js, communicates through Telegram, calls Claude or GPT to complete tasks, and remembers history across restarts.
Prompt
What it is: MimiClaw packs a complete set of AI agent capabilities—reasoning, tool use, and reading and writing memory—into an ESP32-S3 chip that does not run Linux. It is implemented in pure C, sends and receives messages through Telegram,
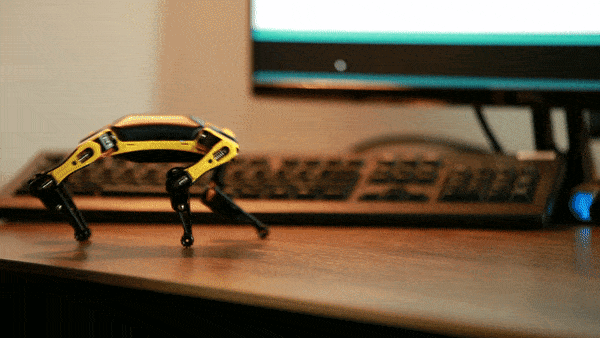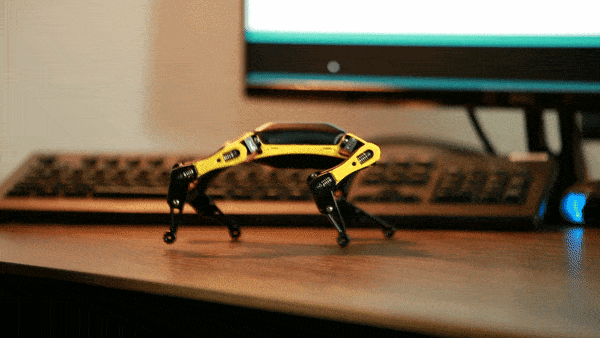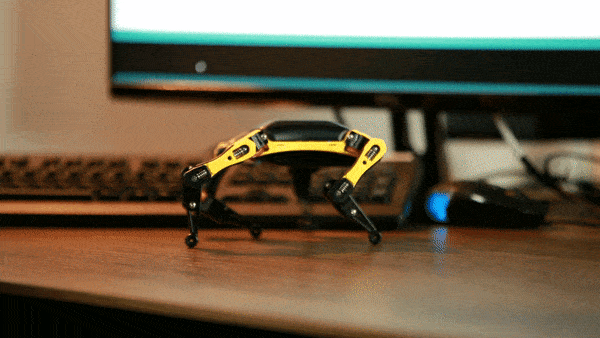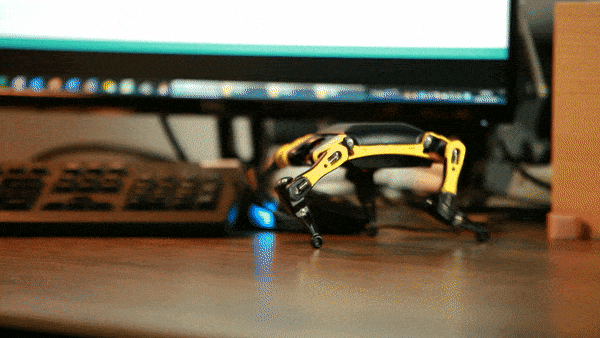
An open-source quadruped robotics framework created by Petoi. The same codebase drives both the Bittle robot dog and the Nybble robot cat, handling gait coordination, servo control, and IMU sensor fusion.
Prompt
What it is: OpenCat is an open-source Arduino + Raspberry Pi quadruped robotics framework maintained by Petoi. Founder Rongzhong Li began developing it in a Wake Forest University dorm room in 2016, with the goal of making agile quadruped r
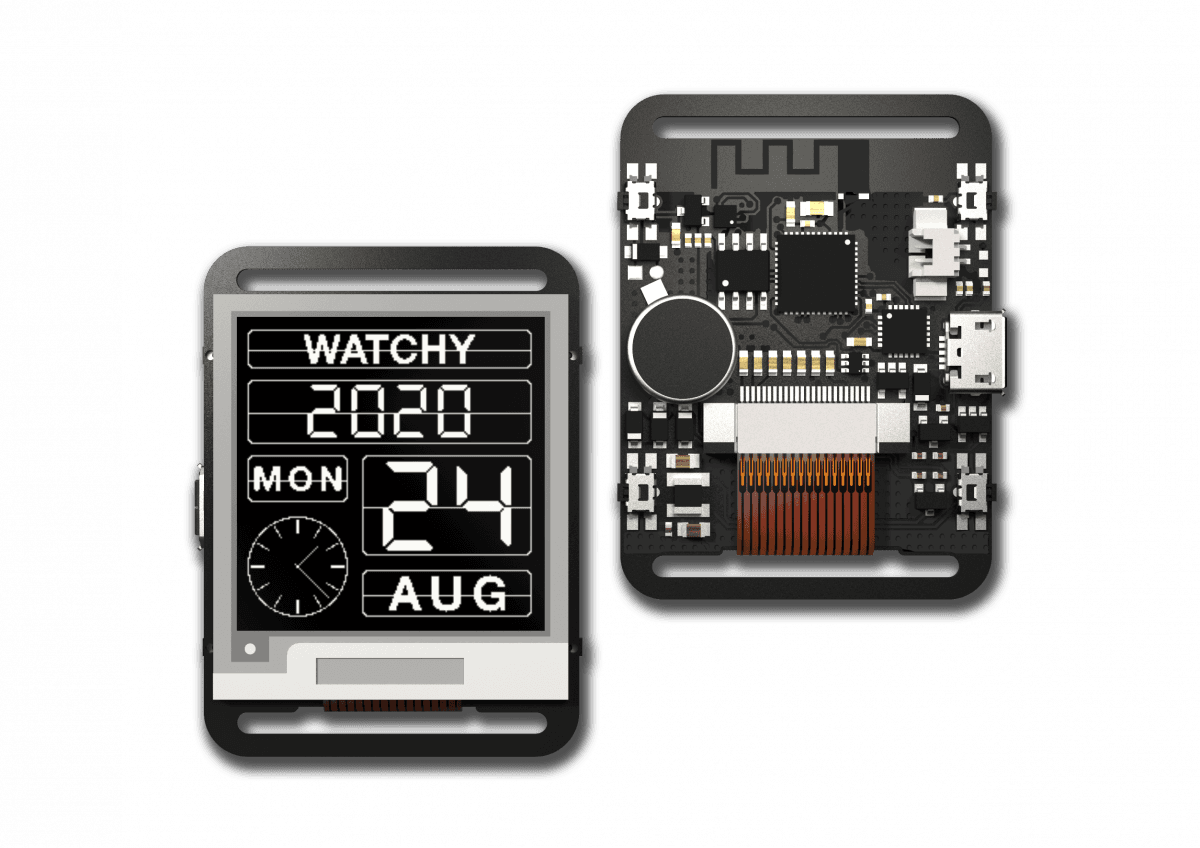
A fully open-source E-Ink watch with publicly available schematics, PCB designs, and firmware. Finished units or component kits can be purchased through official channels and flashed with custom firmware. Launched in 2019, it remains available today.
Prompt
What it is: Watchy is a fully open-source E-Ink smartwatch whose hardware designs and firmware are publicly available. Finished products and accessories are still officially sold through channels including Mouser, The Pi Hut, and Crowd Supp
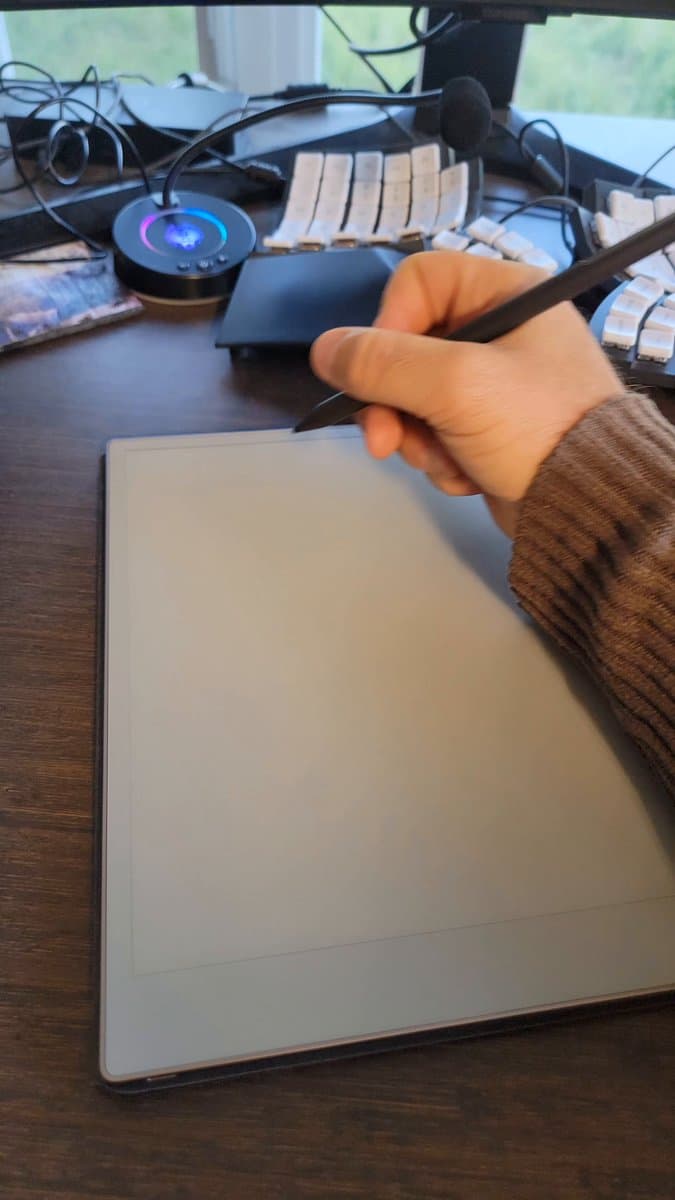
An AI journaling app for the reMarkable Paper Pro. After you pause while writing, the page absorbs the ink, then the AI writes its reply stroke by stroke in handwriting. There is no on-screen UI; interaction is entirely tactile.
Prompt
What it is: riddle is an AI journaling app that runs on the reMarkable Paper Pro e-paper tablet: write with the pen, and after you pause, the page “drinks” your ink. After a moment of thought, the AI writes its reply back onto the page stro
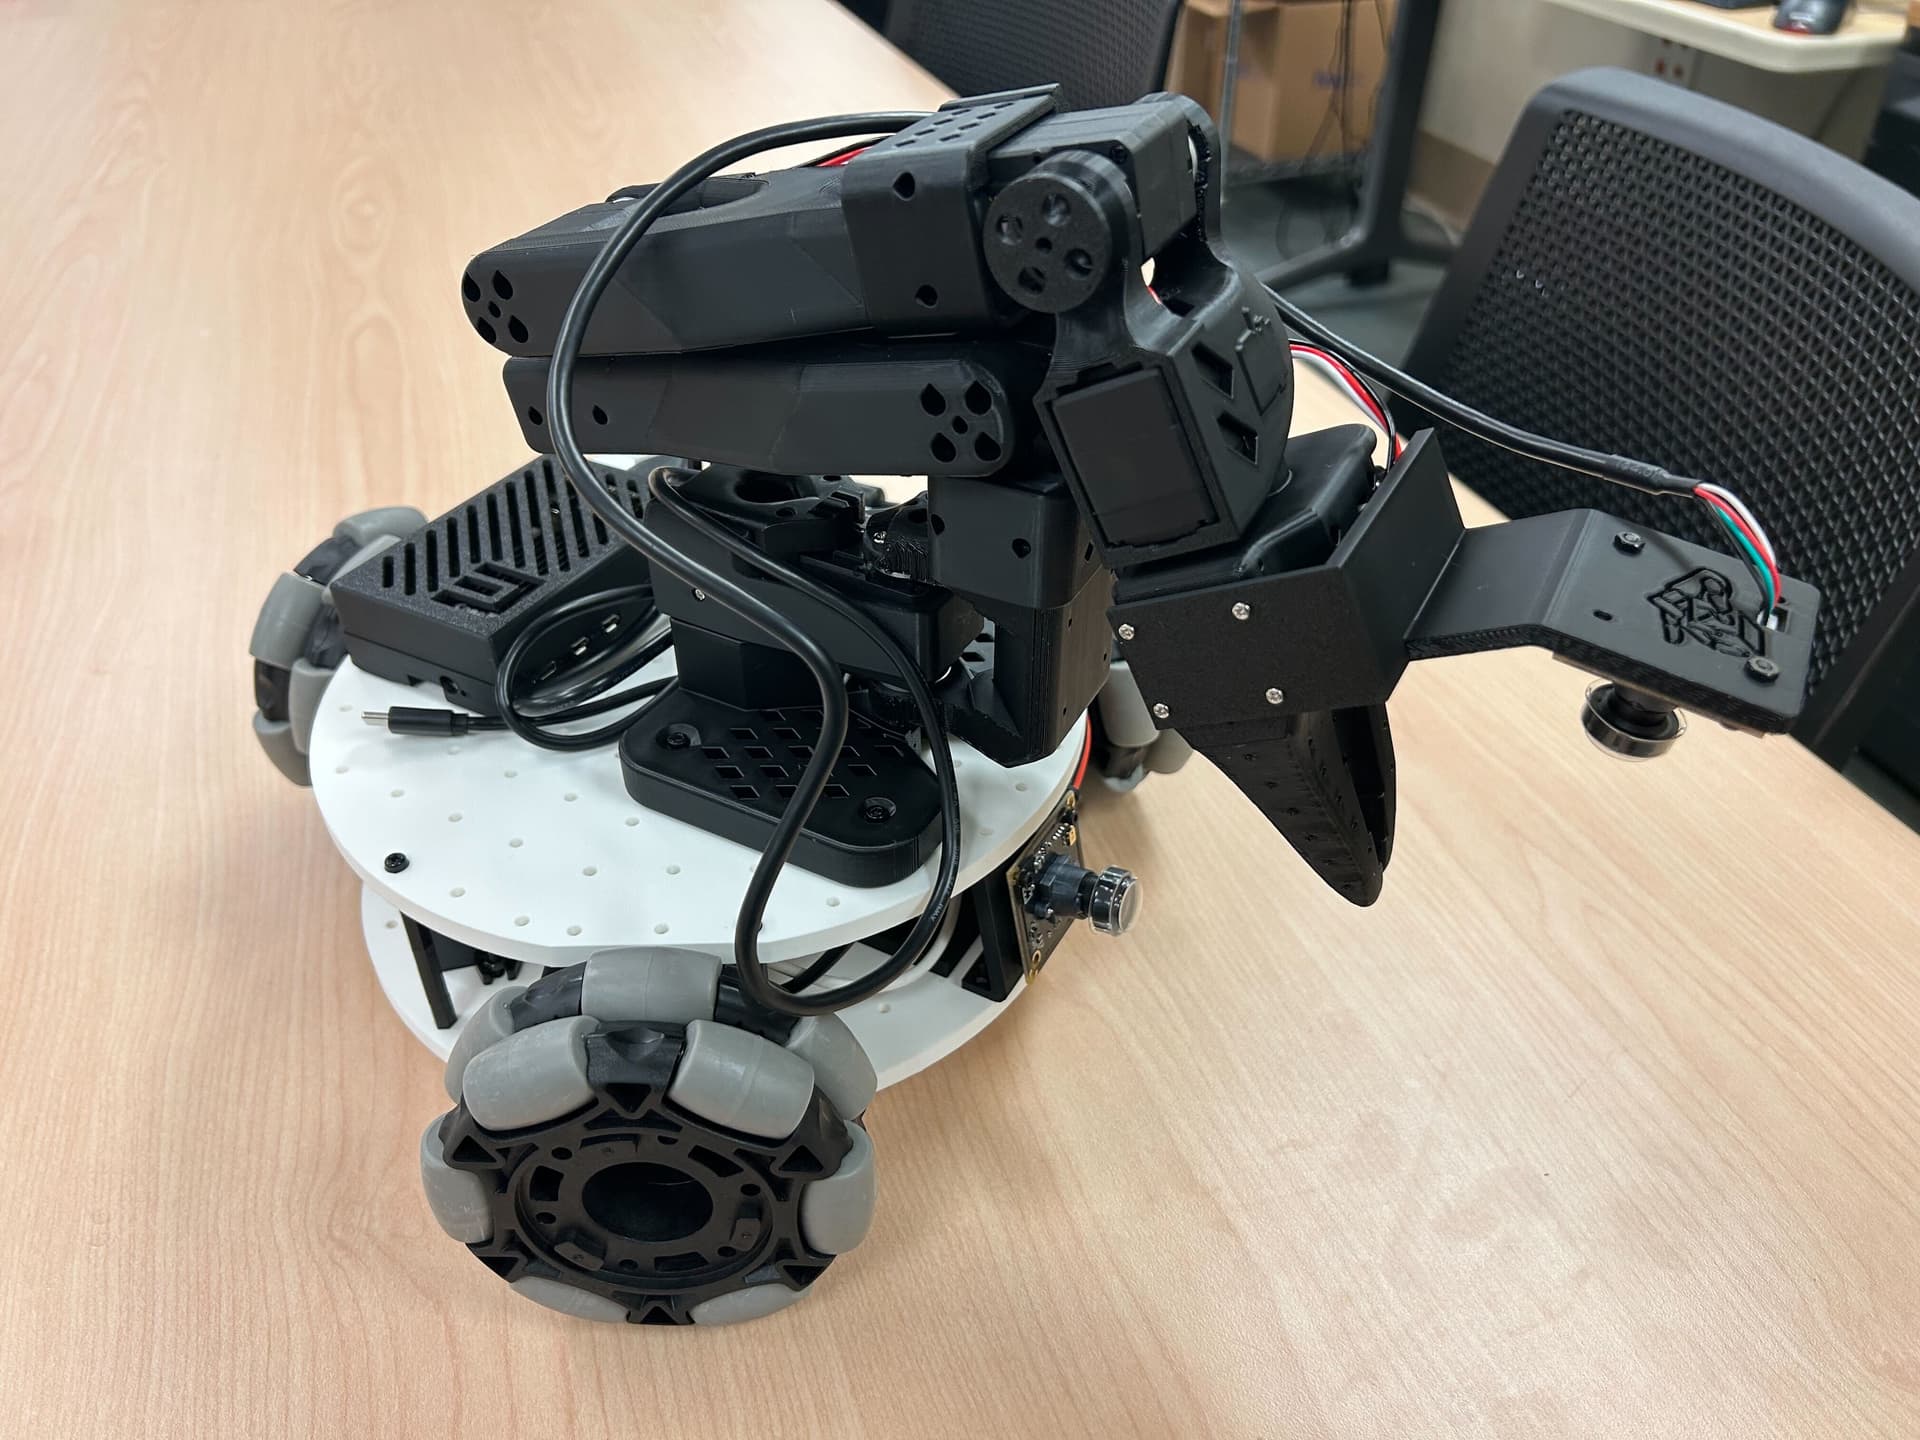
A low-cost mobile robotic arm combining a three-wheel omnidirectional base with a SO-ARM101 robotic arm. It works with the LeRobot library for teleoperation and data collection, costing approximately $482 for the complete 12V version and $499 for the 5V version.
Prompt
What it is: LeKiwi is a low-cost mobile manipulation platform created by the SIGRobotics club at the University of Illinois Urbana-Champaign. It combines a three-wheel omnidirectional Kiwi drive base with a SO-ARM101 robotic arm and later b
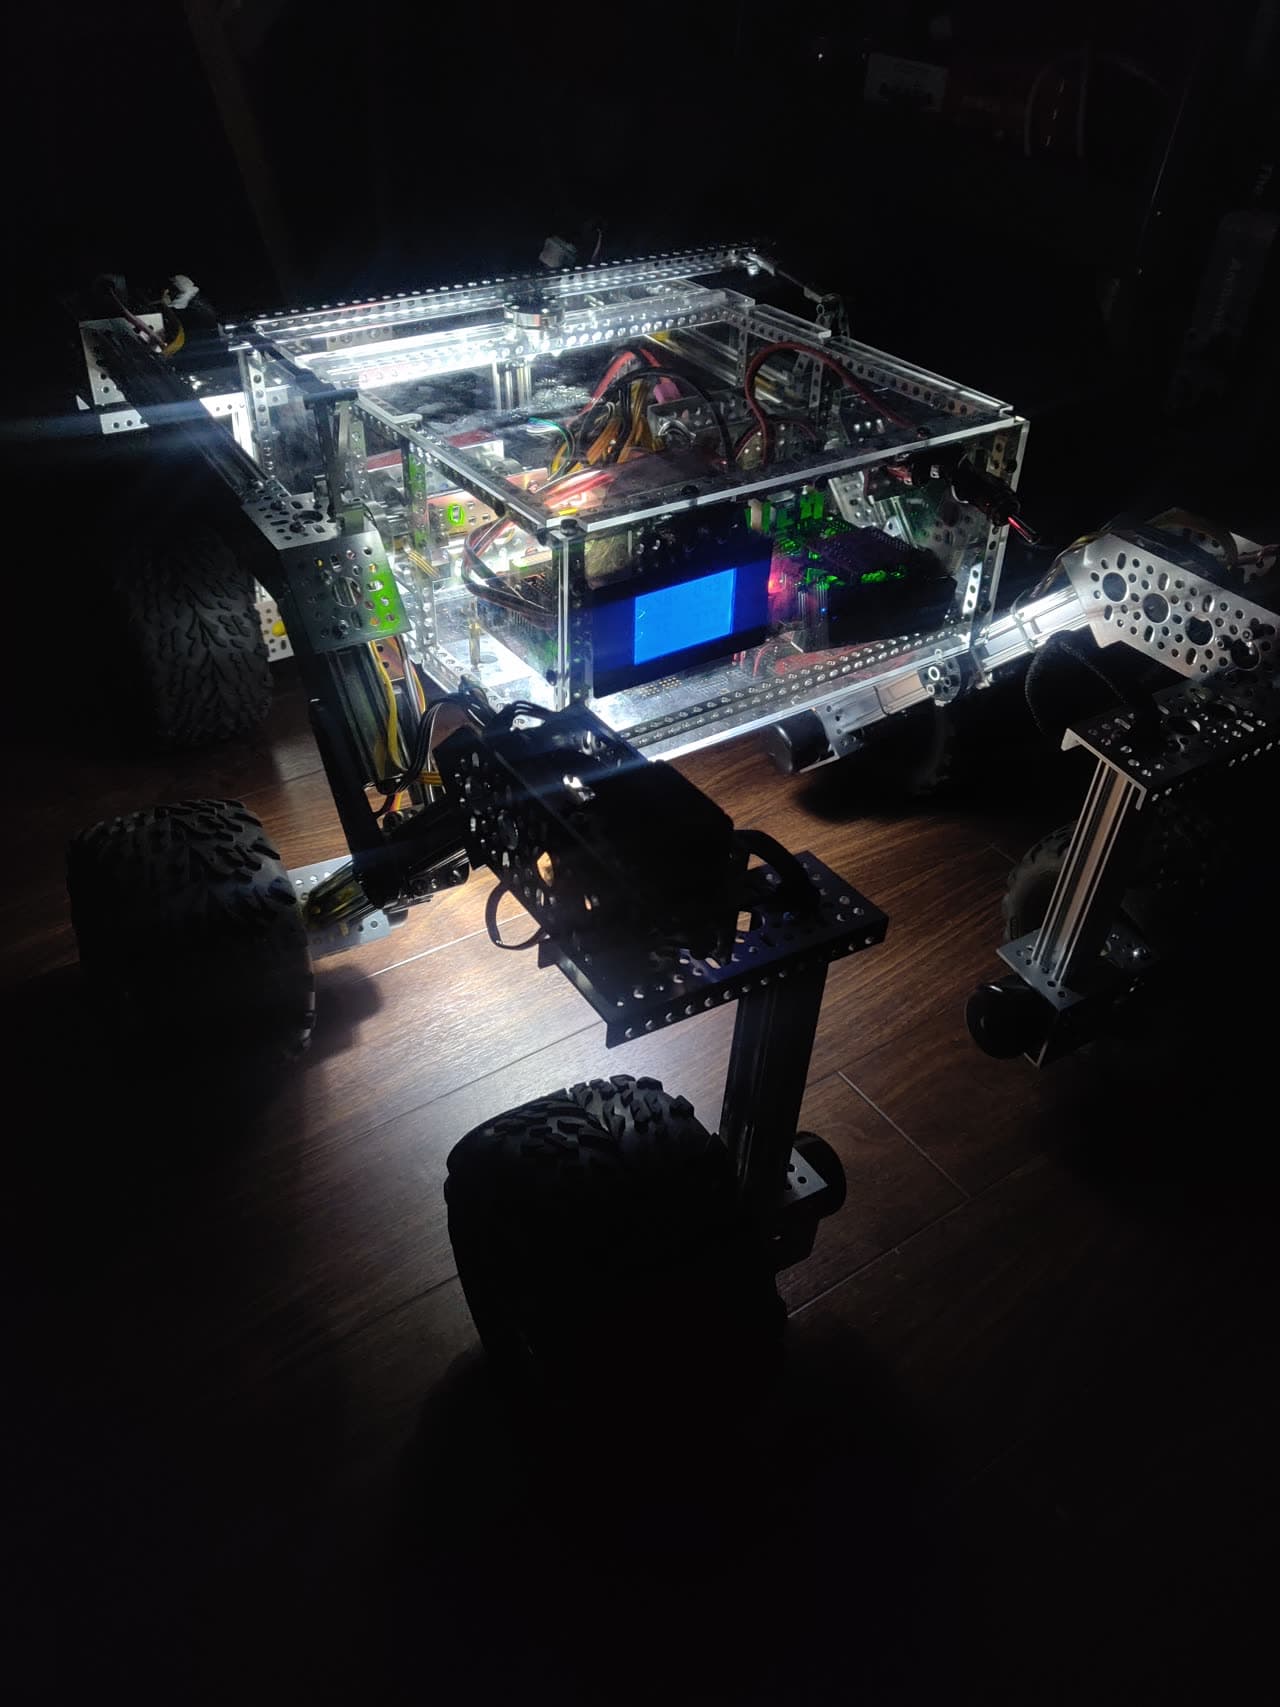
A complete hardware design released by JPL for a six-wheeled Mars rover. Its rocker-bogie suspension and differential pivot keep every wheel in contact with the ground while climbing. A Raspberry Pi serves as the brain, and the full build costs about $1,600.
Prompt
What it is: The Open Source Rover is an open-source hardware project released by NASA JPL. It is a scaled-down replica of the six-wheeled rover design JPL uses for Mars exploration, built entirely from consumer-grade commercial off-the-shel
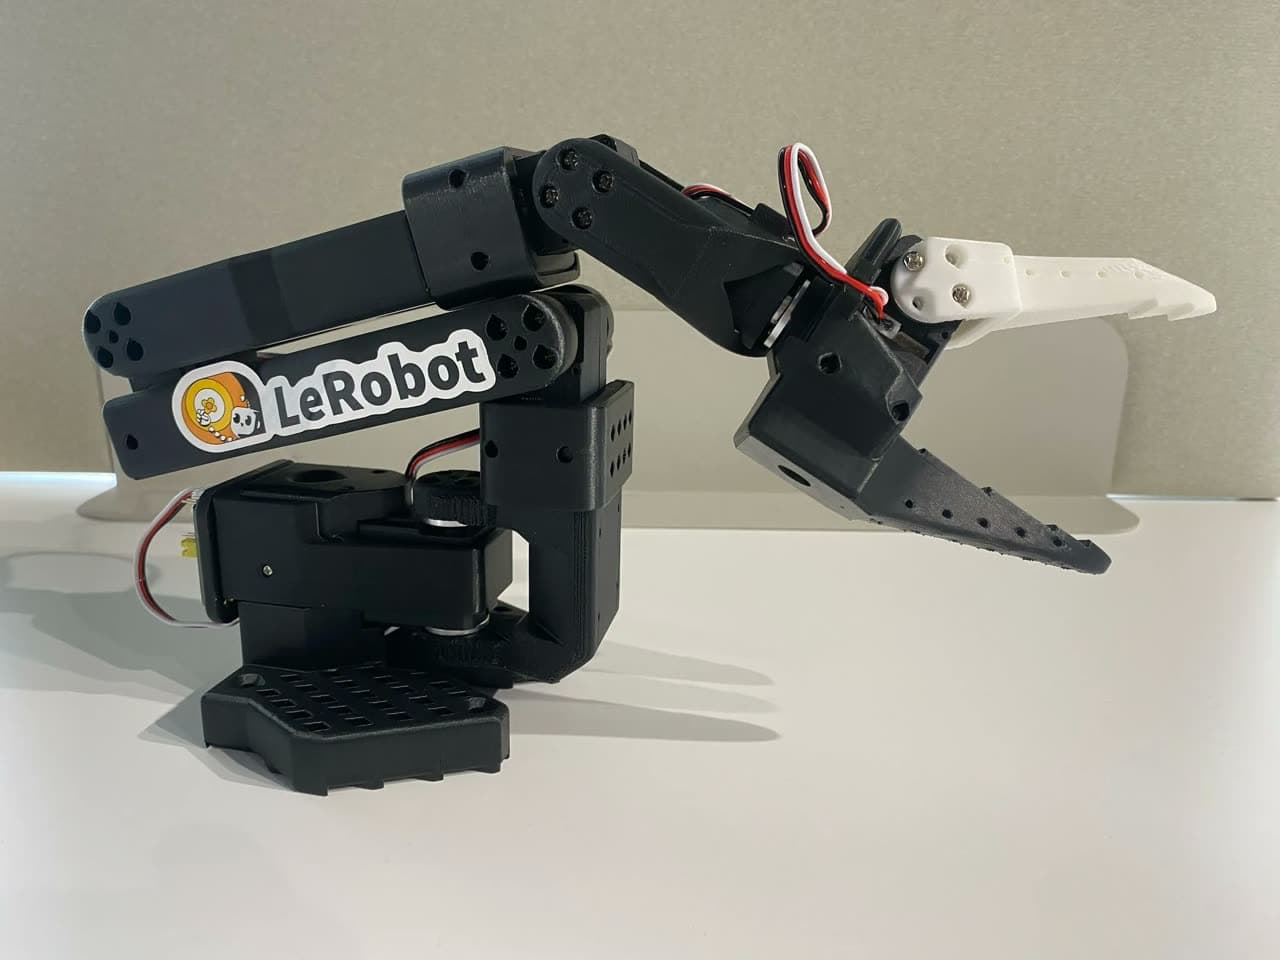
A low-cost standardized robotic arm kit. A leader and follower arm work with the LeRobot library for teleoperation and imitation-learning data collection. The full system can be assembled from online purchases and 3D-printed parts, with both arms costing about $230.
Prompt
What it is: The SO-101 is a standardized open-source robotic arm developed by RobotStudio in collaboration with the Hugging Face LeRobot team. It is the successor to the SO-100, with improved cable routing and assembly that does not require
A Skill is a derived reading layer. Every claim must trace back to published Cases.